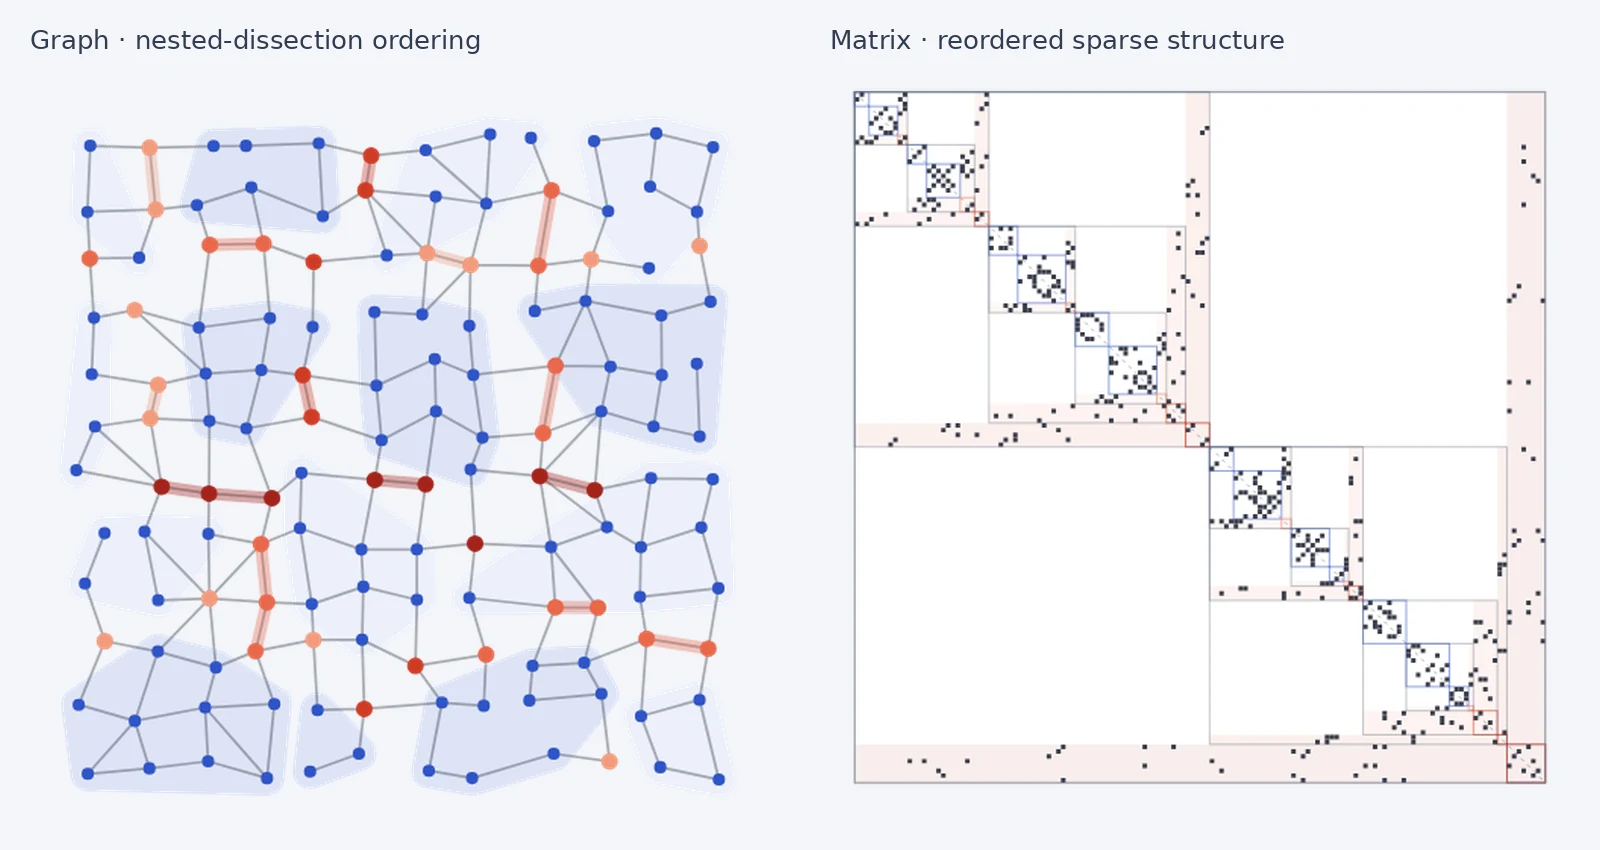
The public PATHPACK explainer showing an illustrative graph and its reordered sparse matrix
Illustrative graph ordering and sparse matrix structure · PATHPACK.jl documentation · Full-size figure ↗

Submitted · Research manuscript · 2026

Direct Solution of Algebraic Path Problems

Richard Samuelson, Itay Kadosh, James P. Fairbanks

Semiring-based sparse algebraic path algorithms unify shortest paths, widest paths, and reachability, with open-source Julia implementations for CPUs and NVIDIA GPUs.

PATHPACK.jl is the accompanying software for this manuscript. Its documentation includes algorithms, examples, and the CPU and GPU interfaces.

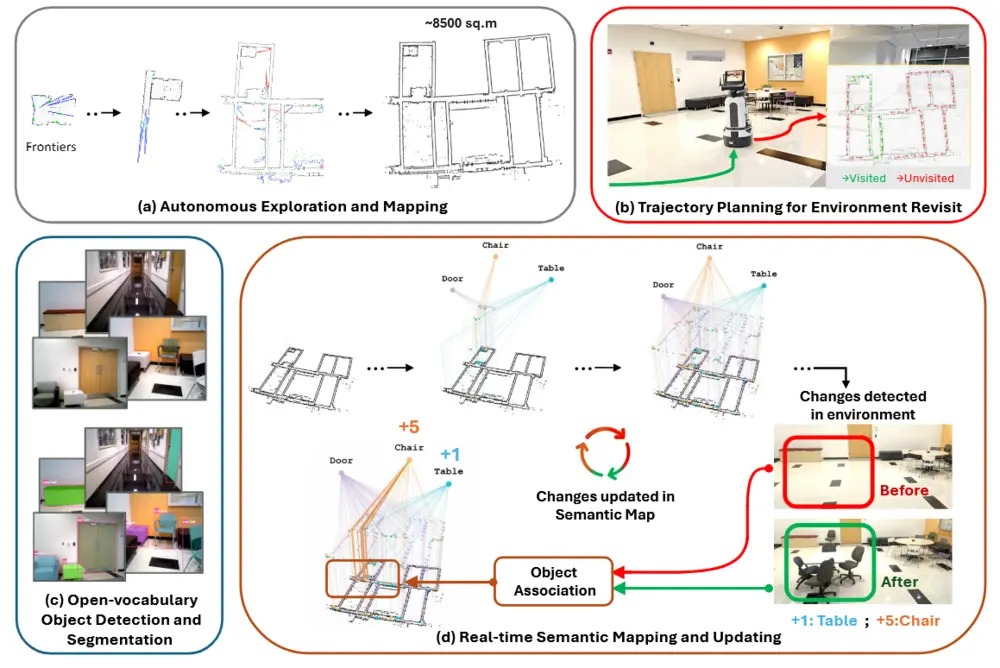
AutoX-SemMap overview showing Fetch robot mapping and semantic object updates
Persistent semantic mapping system · AutoX-SemMap team · Full-size figure ↗
Watch the Fetch exploration demo

A silent recording of the robot exploring and building an indoor map.

Accepted · IROS 2026 WORLDS Workshop · 2026

Build Once, Monitor Continuously: Persistent Semantic Mapping via Autonomous Exploration and Open-Vocabulary Object Updates

Sai Haneesh Allu, Itay Kadosh, Tyler Summers, Yu Xiang

A Fetch robot builds a geometric map once, then updates an open-vocabulary semantic object graph across revisits as objects move, appear, or disappear.

My contributions include the RGB-D open-vocabulary perception pipeline and semantic object association and update logic.

Paused frame from the official RPX dataset showcase
Official RPX dataset showcase · RPX authors · CC BY 4.0 · Full-size figure ↗

Submitted · ICRA 2027 · 2026

Same Scene, Different Story: Evaluating Robot Perception Across Scene Phases in the Wild

Jishnu Jaykumar P*, Itay Kadosh*, Narendhiran Vijayakumar*, Srinanditha Kamath, Sai Haneesh Allu, Govind Tyagi Rangappa, Animesh Maheshwari, Jikai Wang, Yu Xiang

* Equal contribution

A real-world perception benchmark across scene changes: 100 scenes, 70 objects, and 133,121 frames, with 49 models tested in 65 model–task evaluations.

Six tasks cover image depth, video depth, object tracking, relative camera pose, general VQA, and in-context VQA. The dataset includes over 5.2 million VQA question records.

Figures, findings, and demonstration
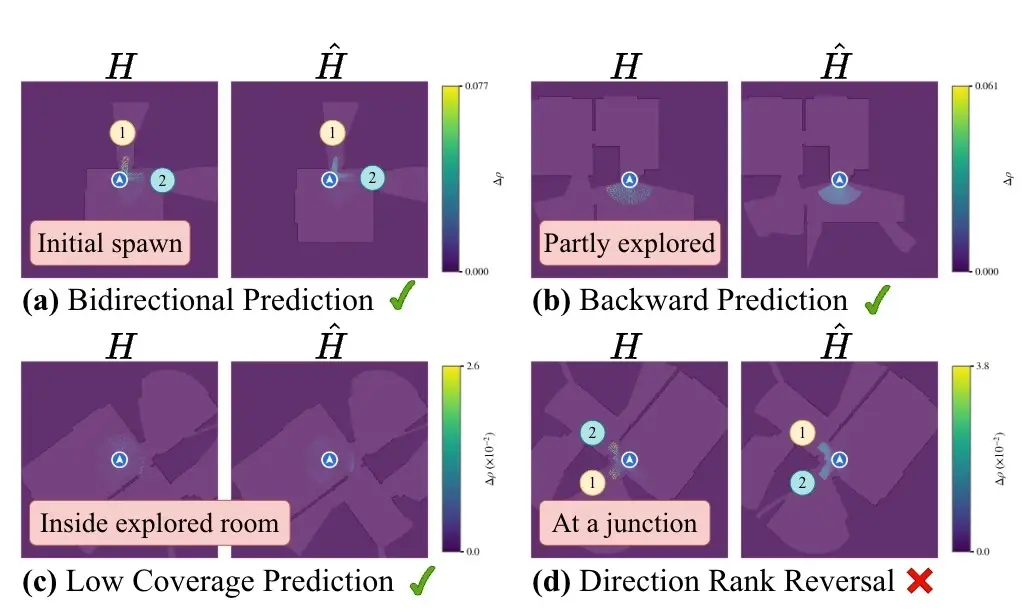
Official IntelX coverage-gain targets and predictions, with a direction-ranking failure case
Coverage-gain targets and predictions, including a failure case · IntelX team · Full-size figure ↗

Submitted · ICRA 2027 · 2026

IntelX: Autonomous Indoor Exploration via Local Coverage Gain Prediction and Structure-Aware Planning

Saurav Dosi, Itay Kadosh, Yu Xiang

A U-Net predicts local coverage gain from partial maps, guiding memory- and structure-aware planning for efficient indoor robot exploration.

The public implementation connects coverage-gain heatmaps to candidate exploration directions, junction-aware planning, and frontier fallbacks.

Ongoing research

Work in progress

Questions and implementations under active investigation.

  • GPU-accelerated tensor-network contraction for quantum circuit simulation.
  • Dynamic sparse Cholesky factorization on GPUs.
  • GPU nested dissection with minimum-fill ordering for leaf problems.
  • Minimum-degree ordering complexity analysis: proposed O(mn) time and linear space; proof in progress.
  • GPU-accelerated C-set homomorphism search for typed structured graphs.

Selected projects

Coursework and experiments

ARMoR

A robotics course project exploring arm-driven mobility on a passive omni-wheel platform, with simulation in NVIDIA Isaac Sim.

Mathematical computing

A graduate coursework report, kept separately from the research publication list.