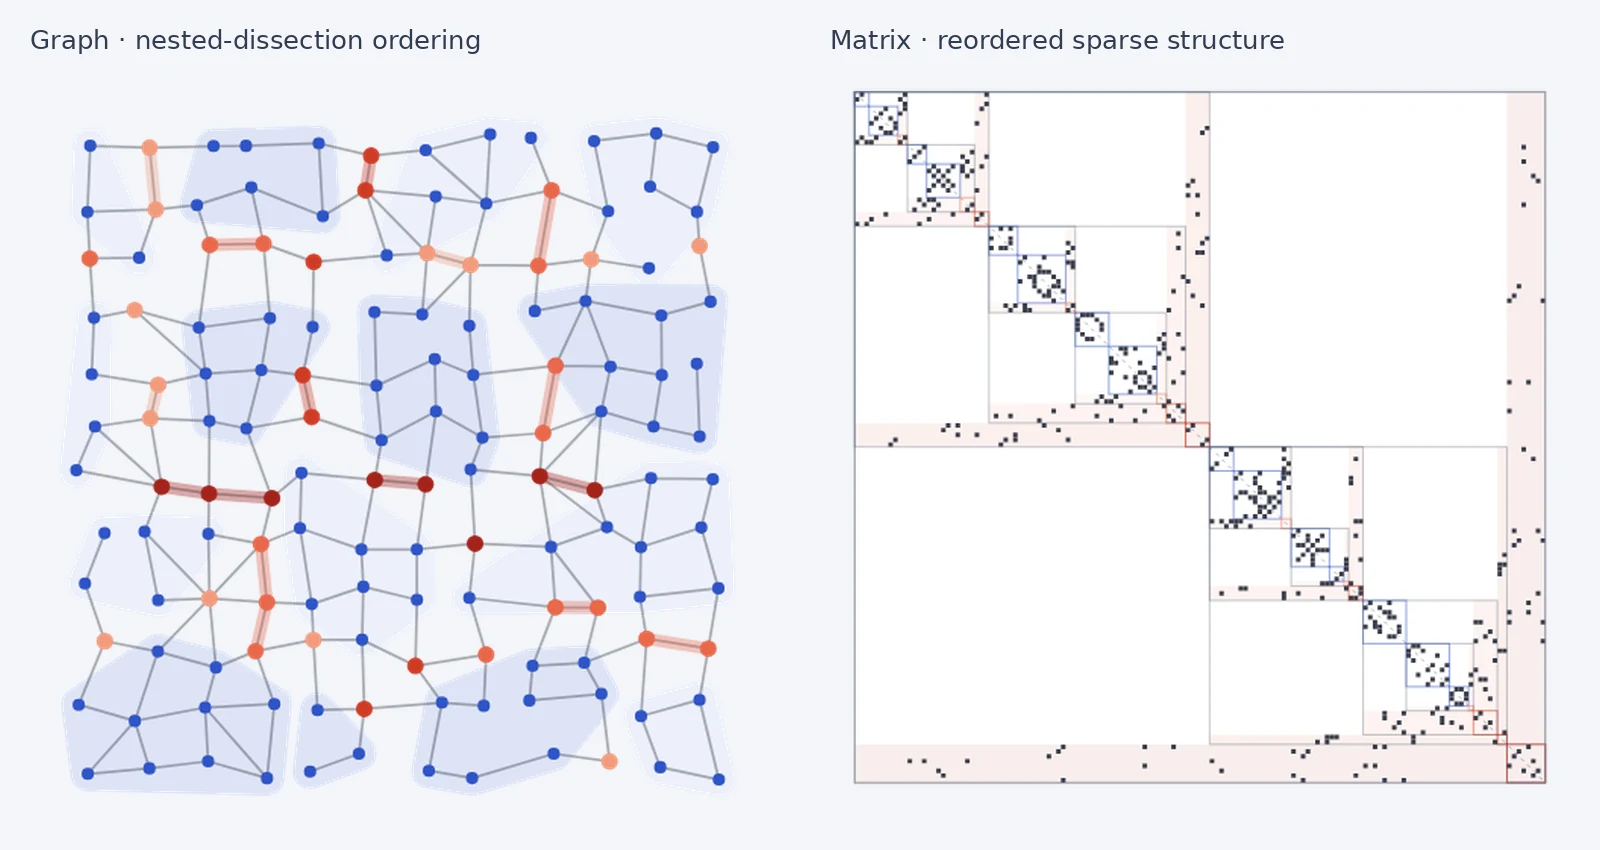
Direct Solution of Algebraic Path Problems
Semiring-based sparse algebraic path algorithms unify shortest paths, widest paths, and reachability, with open-source Julia implementations for CPUs and NVIDIA GPUs.
Ph.D. Student · University of Florida
I’m a Ph.D. student in Mechanical and Aerospace Engineering at the University of Florida, advised by Prof. James P. Fairbanks in the GATAS Lab. My research focuses on sparse numerical algorithms, GPU computing, graph algorithms, and robotic perception. I also work on rigorous evaluation of AI in scientific and embodied settings.
Semiring-based sparse algebraic path algorithms unify shortest paths, widest paths, and reachability, with open-source Julia implementations for CPUs and NVIDIA GPUs.
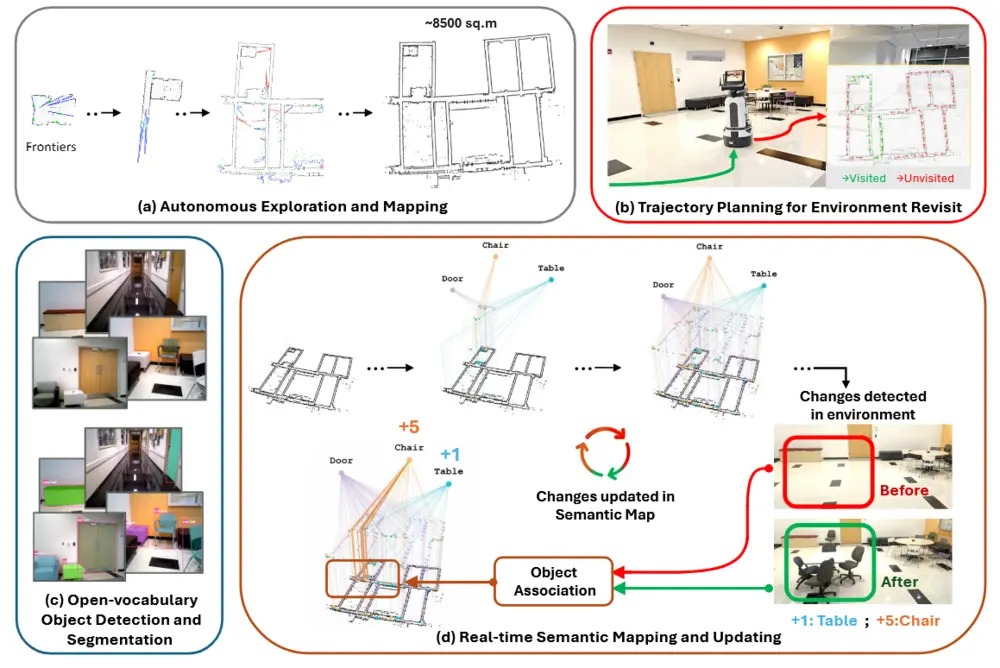
A Fetch robot builds a geometric map once, then updates an open-vocabulary semantic object graph across revisits as objects move, appear, or disappear.
* Equal contribution
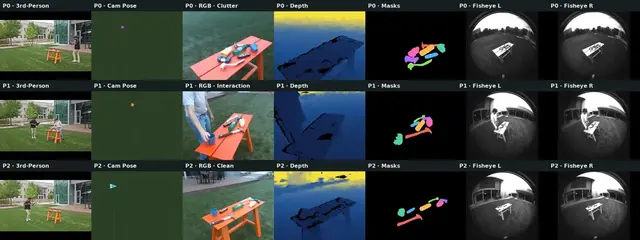
A real-world perception benchmark across scene changes: 100 scenes, 70 objects, and 133,121 frames, with 49 models tested in 65 model–task evaluations.
Figures, findings, and demonstration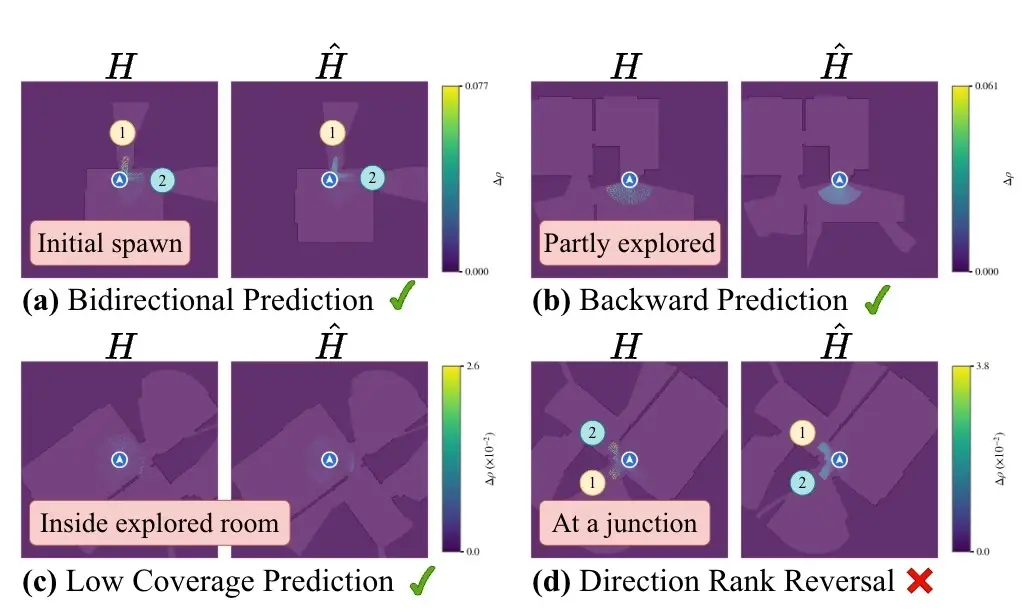
A U-Net predicts local coverage gain from partial maps, guiding memory- and structure-aware planning for efficient indoor robot exploration.
Sparse algebraic path algorithms expressed through semiring linear algebra.
A library for constructing and computing with cellular sheaves and sheaf Laplacians.
Sparse linear algebra, algebraic path problems, and parallel numerical methods that use computational structure efficiently.
Graph algorithms, elimination orderings, and structured mathematical representations for scientific problems.
Robot perception, exploration, and rigorous evaluation of AI in scientific and embodied settings.
2026 · Workshop acceptance
Build Once, Monitor Continuously accepted at the IROS 2026 WORLDS Workshop.
2026 · Open software
PATHPACK.jl is public, with CPU and NVIDIA GPU algorithms and documentation.
2026 · Benchmark release
RPX data and evaluation tools are available on Hugging Face and GitHub.